Scikit-Robot – A Flexible Framework for Robot visualization and programming in Python
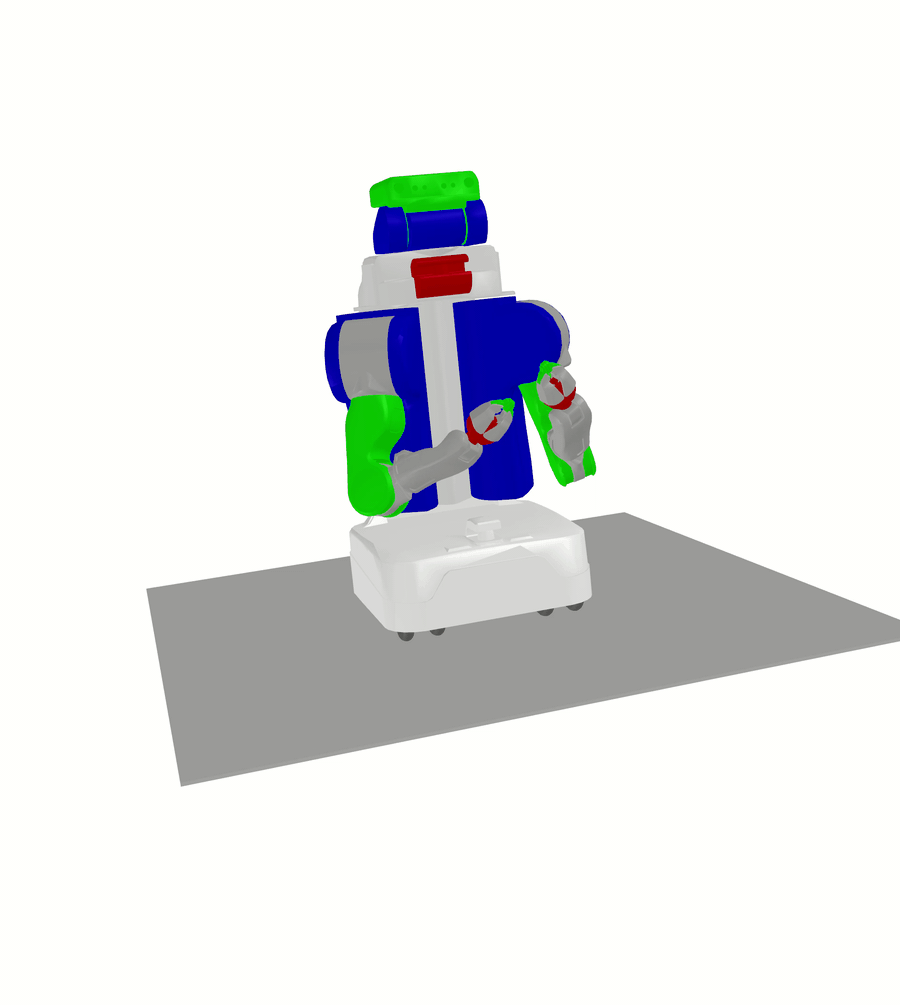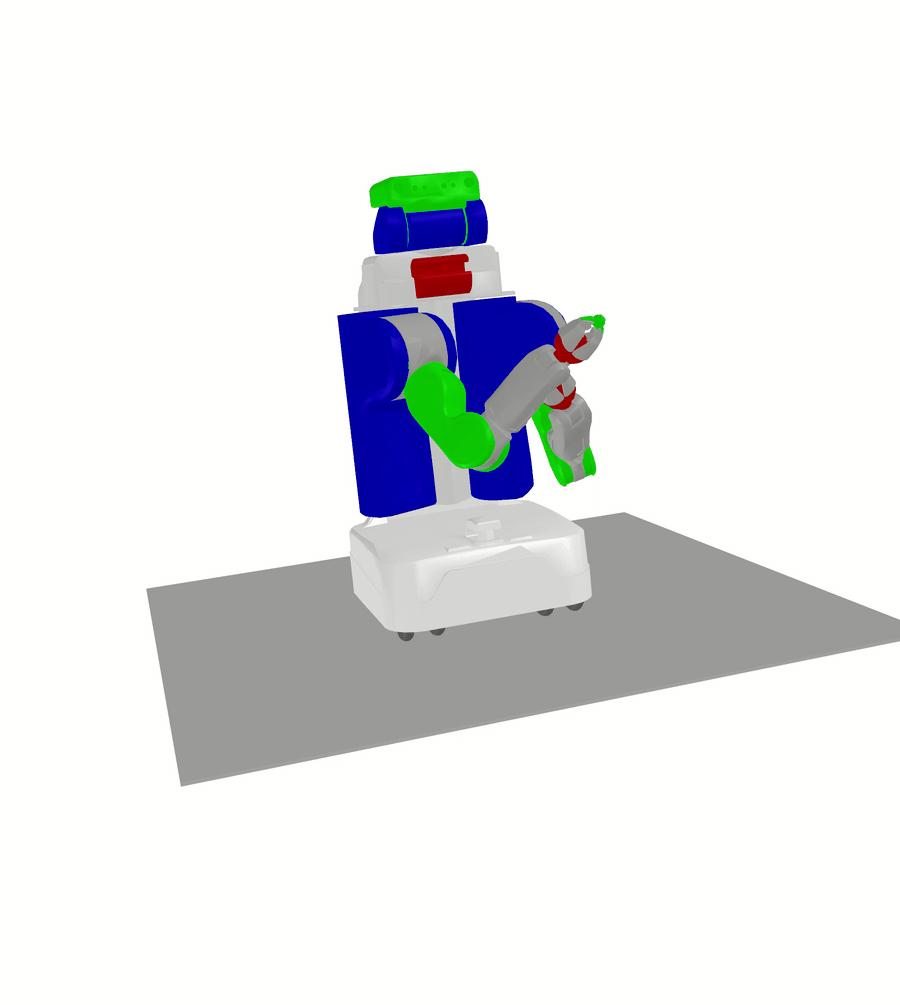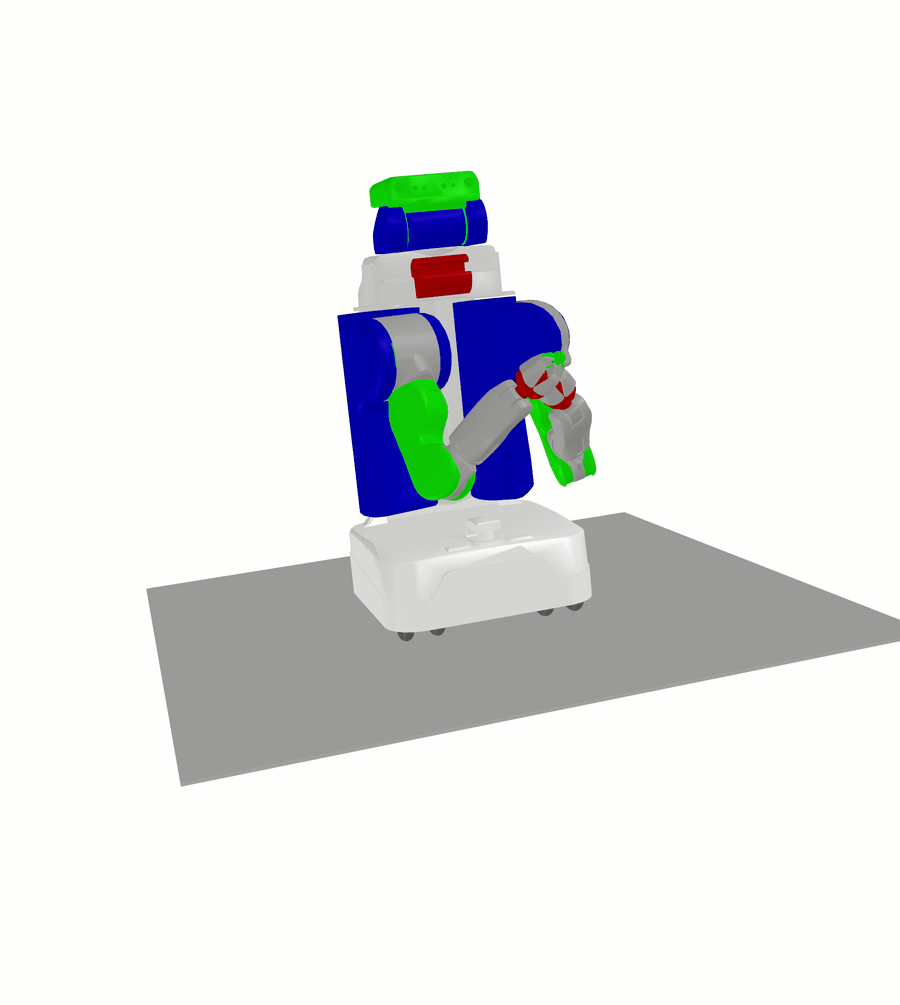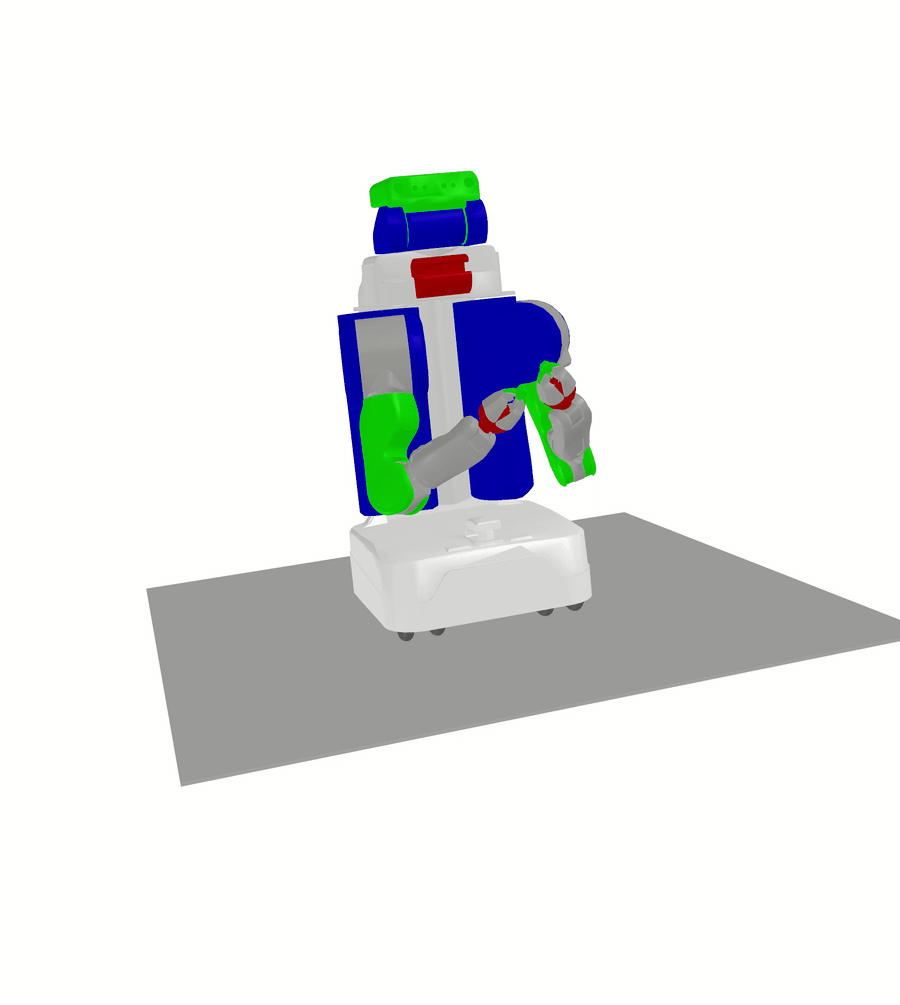
Scikit-Robot is a simple pure-Python library for loading, manipulating, and visualizing URDF files and robot specifications. For example, here’s a rendering of a PR2 robot moving after being loaded by this library.
Getting Started
- Installation and Setup Guide
- Quick Start
- Installation
- Loading Your First Robot
- Moving Robot Joints
- Understanding the Robot Structure
- Simple Inverse Kinematics
- Animating Robot Motion
- Working with Other Robot Models
- Adding Objects to the Scene
- Using Coordinate Frames
- Saving and Loading Robot States
- Next Steps
- Complete Example
- Troubleshooting
- Getting Help
Understanding Scikit-Robot
User Guide
- Tutorials
- Usage Examples
- Examples Explained
- Robot Models Visualization
- PR2 Inverse Kinematics
- Collision-Free Trajectory
- Self-Collision-Free Trajectory
- Trimesh Scene Viewer
- PyBullet Interface
- Signed Distance Functions
- Swept Sphere
- Batch Inverse Kinematics
- Reachability Map
- Base Placement
- Joint Limit Tables
- Grasp and Pull
- Trajectory Interpolation
- Command Line Interface (CLI)
Reference
Development